
Proception at ICRA 2026: Our First Public Exhibition — Vienna, Austria
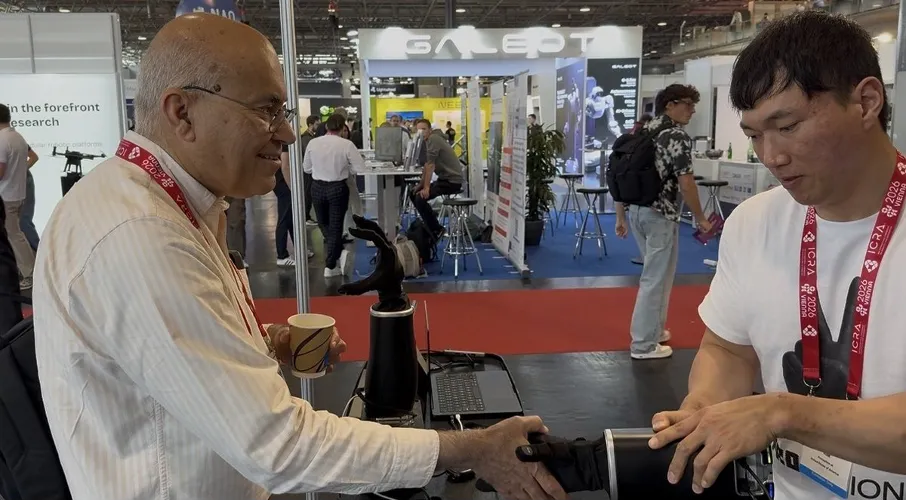
ICRA 2026 in Vienna was a milestone for Proception: our first time showing Proception Hand publicly. We brought the hand to the world's largest robotics conference knowing it would face the most demanding audience possible, and we came away more energized than we expected.
 Proception
What Makes Proception Hand Different
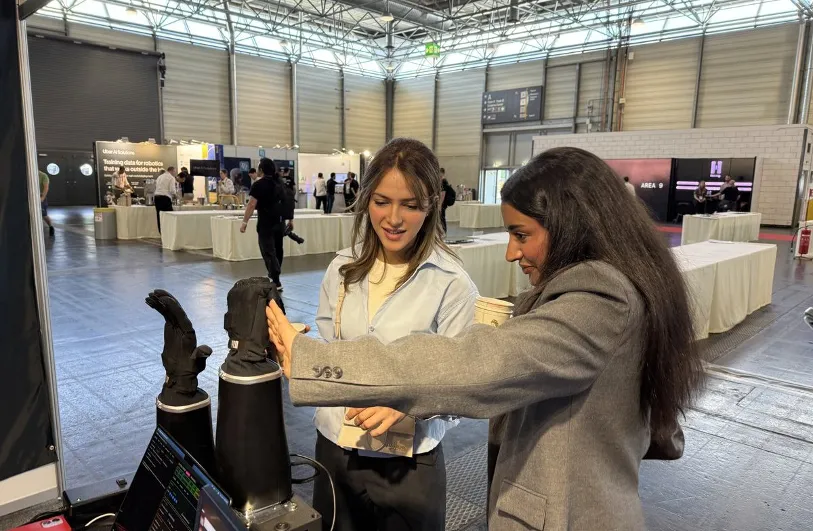
Proception Hand is a 22-degree-of-freedom, tendon-driven robotic hand with full-hand tactile sensing across every finger and the palm. It matches human hand strength and form factor — not a scaled-up industrial gripper, but a hand that looks, moves, and performs like the real thing. Its tendon-driven architecture produces dexterous, lifelike motion that closely mirrors natural human hand kinematics, while the distributed tactile sensing lets it perceive contact, pressure, and texture across the entire hand surface. That combination drew a continuous flow of visitors to our booth throughout the week. People could interact with Proception Hand directly: grip it, prod it, and feel first-hand what full-hand tactile feedback actually means in practice.
The Response from the Community
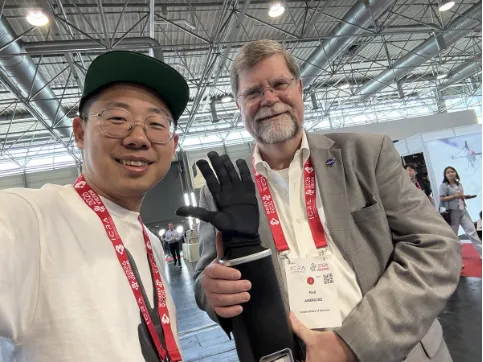
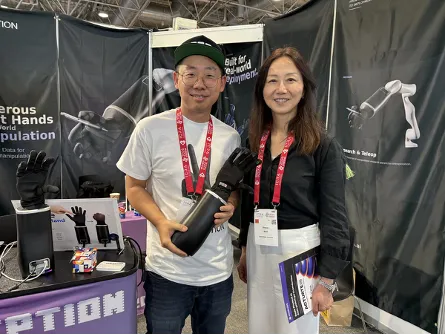
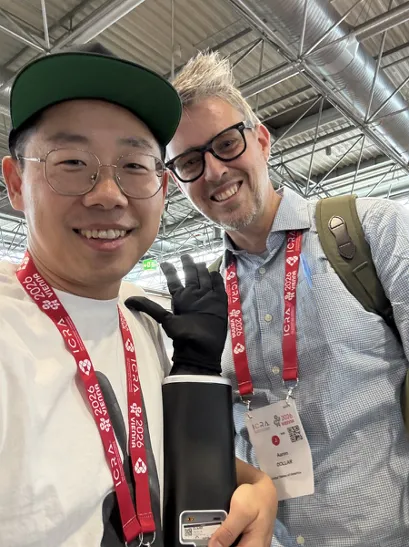
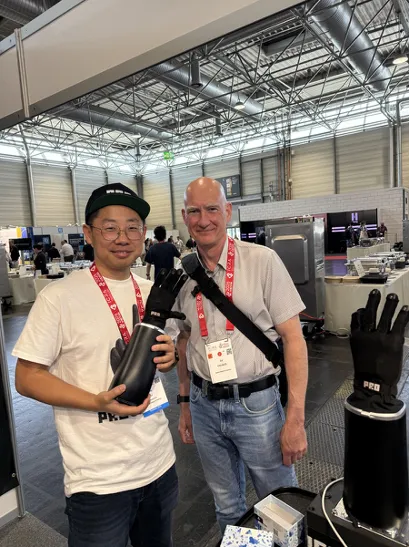
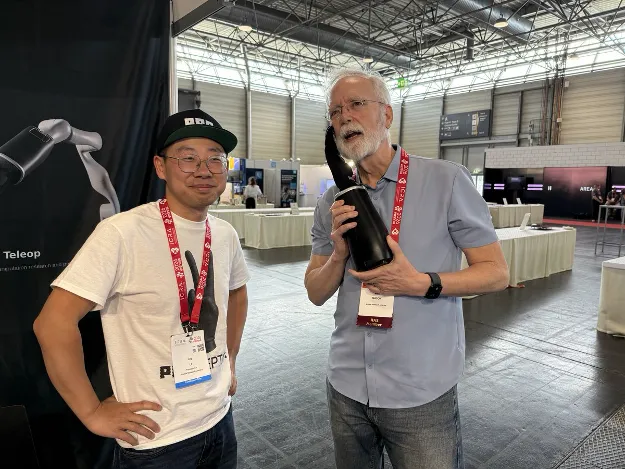
We were not expecting quite the roster of visitors we got. Robert Ambrose, who led the development of NASA's Robonaut hand and has spent decades at the frontier of humanoid robotics, tried the hand and gave it a single rating: "A+." Zhenan Bao, whose lab at Stanford has produced some of the most important work in artificial skin and tactile sensing, looked at Proception Hand's sensing system and said: "This is amazing." Matthew Mason of Carnegie Mellon, Aaron Dollar of Yale's GRAB Lab, Ed Colgate of Northwestern, and Jitendra Malik of UC Berkeley all stopped by and spent real time with the technology. For a first public outing, we could not have asked for better.
 Proception
 Proception
 Proception
 Proception
 Proception
Live Demos and Broader Conversations
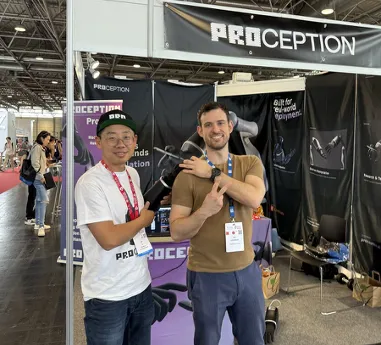
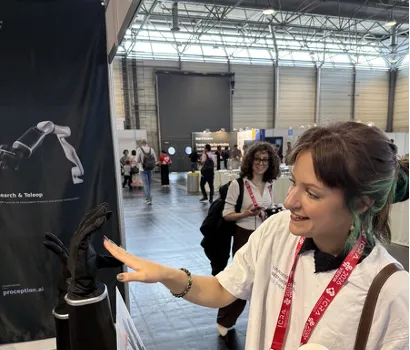
Outside of those conversations, the booth was busy. Researchers, students, and engineers stopped throughout the conference to interact with Proception Hand directly, and many of those conversations turned into longer discussions about where the technology could go. There was a genuine appetite from people working across humanoid robotics, teleoperation, prosthetics, and manipulation research.
 Proception
 Proception
 Proception
See Proception Hand in Action
Footage from the exhibition:
What's Next
ICRA 2026 was our starting point, not a destination. We are grateful to everyone who stopped by, tried the demo, and took the time to talk. Those conversations have already fed back into what we are building. More to come soon.